Mobile Robotics & Autonomy

Built to move.
Built to last.

Olive brings synchronized sensing, robot-local intelligence, resilient connectivity and fleet-ready observability into one integration baseline—robust, reliable, responsive and designed to remain predictable from prototype to operation.

Robot-native integration Low-latency edge intelligence Fault-aware local control Fleet-ready observability
Autonomous mobile robot moving medical supplies through a hospital corridor Robot health / nominal Control / robot-local
One dependable baseline. Multiple missions.

Different missions.
The same trusted core.

Build application-specific machines on a repeatable foundation for mobility, sensing, intelligence, communication, diagnostics and lifecycle operations.

Autonomous mobile robot transporting parcels inside a delivery truck
Intralogistics

Warehouse flow

Move totes, parcels and work-in-progress through repeatable, observable missions.

Autonomous mobile robot spraying crops in a greenhouse
Outdoor & agriculture

Precision field work

Bring payload control and local autonomy into variable operating environments.

Autonomous mobile robot with a manipulator picking goods in a store aisle
Mobile manipulation

Retail picking

Coordinate navigation, payload I/O and arm workflows on one robot graph.

Autonomous mobile robot carrying prepared food in a commercial kitchen
Service robotics

Food operations

Automate structured transport while keeping fast response on the robot.

Autonomous mobile robot transporting industrial totes across a factory floor
Manufacturing

Material supply

Connect production logistics to reliable robot state and fleet visibility.

Autonomous mobile robot transporting supplies in a clinical environment
Healthcare

Clinical logistics

Deliver supplies through shared spaces with auditable mission behavior.

Integration-ready robot architecture

One time model. One data fabric.
One trusted baseline.

Olive exposes sensing, edge intelligence, connectivity and mobility through consistent robot-native interfaces—reducing integration friction while keeping timing, diagnostics and system state observable.

Robot graph / responsibility mapSynchronized
Motion sensingTIME-ALIGNED STATE / HEALTH LiDAR + visionRANGE / MAPPING / PERCEPTION Payload I/OACTUATORS / PLC / USER I/O olixCore™ edge intelligenceARM PROCESSING · NPU ACCELERATIONOLIXOS™ · REAL-TIME LINUX · ROS 2 · DDS Localization & SLAMODOMETRY / MAP / STATE ESTIMATION Nav2 & controlPLAN / COSTMAP / MOTION / RECOVERY Edge AI & diagnosticsINFERENCE / HEALTH / LOGGING / OTA Robot communicationsRESILIENT WIRELESS · ETHERNET · LINK HEALTH Fleet operationsMISSIONS / OPEN-RMF / AUDIT
TIME-ALIGNEDsensing and state data
LOW LATENCYrobot-local processing
EDGE AIon-device inference
OBSERVABLEhealth and diagnostics
Determinism by architecture

Fast decisions stay on the robot.
Operations scale above it.

Localization, collision response, motion control, watchdogs and defined fallback behavior remain robot-local. Mission state, telemetry and lifecycle operations cross the fleet link under explicit authority and DDS QoS policies.

Control boundary / responsibility splitRobot-local priority
ROBOT / LOCAL AUTHORITY BOUNDED RESPONSE · LOCAL STATE · DEFINED FALLBACK FLEET / OPERATIONS MISSIONS · OBSERVABILITY · LIFECYCLE LocalizationMAP / POSE / SOURCE TIME Nav2 + motionPLAN / COSTMAP / CONTROL Watchdog + fallbackHEALTH / LIMIT / SAFE STATE Payload controlI/O / ACTUATORS / WORKFLOW olixCoreROS 2 / DDS / OLIXOS C1OBSERVEDLINK Mission orchestrationGOALS / JOBS / TRAFFIC TelemetryHEALTH / MAPS / EVENTS Configuration + OTAVERSION / POLICY / UPDATE Operator + auditAUTHORITY / LOG / REVIEW
COMMAND STATEReliable delivery with deadline and liveliness supervision.
ROBOT TELEMETRYRate-managed before local control workloads are compromised.
HIGH-BANDWIDTH DATAExplicit policies for video, maps and point-cloud traffic.
COMMAND AUTHORITYAuthenticated control and defined loss-of-link behavior.

Engineering boundary: public cellular and Wi-Fi performance varies with operator, spectrum, RF environment, load, routing and topology. Validate the deployed network under representative site conditions, and keep safety-critical stopping functions inside the validated robot safety architecture—not across an uncontrolled WAN.

Resilient robot connectivity

Connected when it matters.
Observable all the time.

olixLink C1 creates a managed communications boundary for mobile robots—combining resilient wireless access, robot-network integration, secure remote operations and link-level diagnostics.
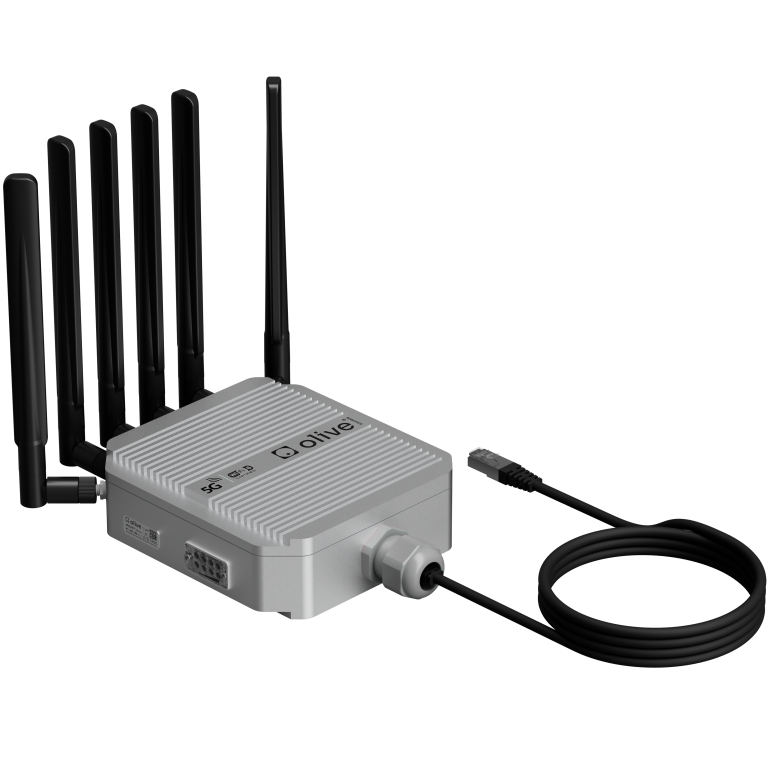
olixLink C1 industrial robot connectivity unit Resilient wireless Industrial robot network ROS 2 diagnostics
MULTI-PATHcommunications resilience
HIGH BANDWIDTHrobot data transport
LOW LATENCYresponsive connectivity
SECURE ACCESSmanaged remote operations
Deployable AMR foundation

Start with a robot.
Finish with your application.

olixBot ANT1 brings mobility, robot-local intelligence, perception and a ROS 2-native autonomy baseline together in one integration-ready platform for payload and application engineering.
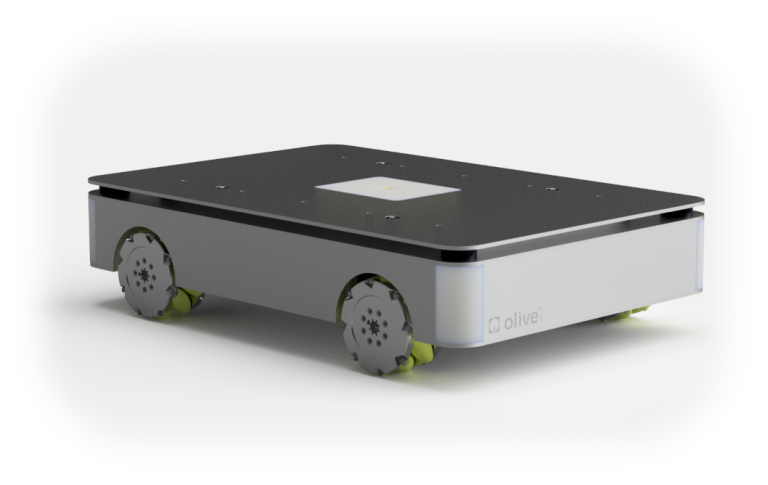
olixBot ANT1 compact holonomic autonomous mobile robot HOLONOMIC MOBILITYagile planar motion ROBOT-LOCAL INTELLIGENCEARM edge compute + NPU ROS 2 / DDS / NAV2robot-native autonomy
PAYLOAD-READYapplication integration
ROBOT-NATIVEconsistent software interfaces
SERVICEABLEobservable modular architecture
FLEET-READYmissions and lifecycle operations
Engineering to fleet operations

Integrate once.
Operate with confidence.

Carry the same robot graph, time model, communication policy and diagnostic baseline from engineering validation through repeatable site deployment and continuous fleet operation.

01

Bench

Validate nodes, frames, source time, QoS and hardware I/O.

02

Robot

Integrate payloads, autonomy behaviors and robot-local fallback.

03

Site

Validate maps, RF coverage, traffic, charging and operations.

04

Fleet

Version configuration, monitor health and govern authority.

Mobile autonomy, engineered for integration

Robust by design.
Observable in operation.

Use Olive as an AMR foundation, adopt selected robot-native components, or integrate the embedded technology stack into your own mobile robot—with predictable interfaces and support across the system lifecycle.

Final performance depends on system configuration, software, payload, environment, network conditions and project requirements. Validate the complete robot under representative operating conditions.

  1. Scope; contractual precedence. This website is published by Olive Robotics GmbH for informational and commercial purposes. Unless expressly agreed otherwise, descriptions, specifications, availability and roadmaps do not constitute a binding offer, independent guarantee or commitment to future functionality. The applicable agreement, including the validly incorporated Terms & Conditions, governs the supply; individual agreements and mandatory statutory information requirements take precedence. Website updates do not amend an existing contract.

  2. Technical data; performance representations. Published measurements apply to the stated product revision, configuration, methodology and operating conditions. Performance may vary with calibration, mounting, firmware, filtering, network conditions and integration. Typical, nominal and illustrative values are not guaranteed limits unless expressly designated and agreed as such. Renderings, application scenes, simulations and AI visualizations are illustrative unless expressly identified as measured results; they do not establish product certification, delivery scope or third-party endorsement.

  3. Intended use; system integration. Products shall be used within their documented intended use and operating limits. The integrator shall assess application suitability and validate the complete system, including timing, interfaces, installation and applicable safety requirements. Component-level declarations do not certify a complete machine or safety function. These provisions do not transfer or exclude duties imposed on Olive Robotics by mandatory law. Refer to the applicable technical documentation and compliance documentation.

  4. Liability; reserved rights. Nothing in these notices excludes or restricts liability for intent or gross negligence, culpably caused injury to life, body or health, fraudulent concealment, an expressly assumed guarantee, or mandatory statutory product liability. Mandatory consumer protections and statutory remedies remain unaffected. Any further allocation or limitation of liability is governed solely by a valid agreement and applicable law; this notice does not establish a blanket exclusion of liability.

  5. Intellectual property; software; external content. Olive Robotics names, marks and proprietary materials remain protected. olive® and OLVX® are registered trademarks of Olive Robotics GmbH. Third-party marks and materials belong to their respective rights holders. No licence is granted beyond rights expressly granted or required by law; applicable open-source licences remain unaffected. Software and AI services are subject to their applicable licence terms. External content is provided by the relevant operator; statutory duties concerning unlawful content remain unaffected. Website access is governed by the applicable Terms of Use.

  6. Data protection; cookies; provider identification. Personal-data processing and the use of cookies or similar technologies are described in the Privacy Policy. Where legally required, consent must be obtained separately before the relevant processing or terminal-equipment access; continued browsing does not constitute consent. These notices neither replace a required consent mechanism nor restrict data-subject rights. Statutory provider information and contact channels are set out in the Imprint.

Olive Robotics icon

Olive Robotics GmbH

Embedded Intelligence for Physical AI

Let’s talk robotics.

Contact our team
Daimlerstraße 7 · 85521 Ottobrunn
Germany

Intelligence in every move.

Copyright © 2022–2026 Olive Robotics GmbH.All rights reserved.

English / International